Boston Dynamics and Google DeepMind teach Spot to reason on industrial inspection rounds
Boston Dynamics has added Google DeepMind's Gemini Robotics-ER 1.6 model to Spot and is betting on industrial inspection. The robot can now look for hazardous spills and debris on its own, read the displays of complex instruments and better judge whether it completed an action. The key question is no longer about impressive demos, but whether this kind of AI can work consistently on real factory floors.
AI-processed from IEEE Spectrum AI; edited by Hamidun News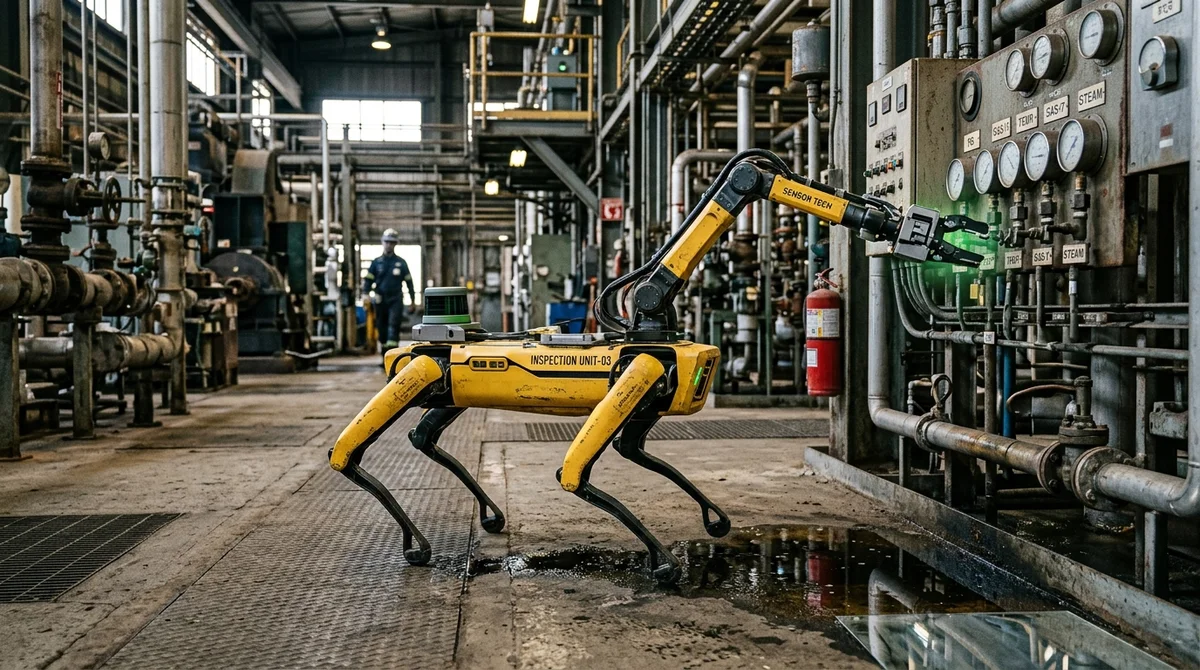

Boston Dynamics is moving Spot out of the category of impressive demos and into a more practical class of industrial robots. The four-legged machine has received Google DeepMind's Gemini Robotics-ER 1.6 model, and it is now supposed to do more than follow commands: it should interpret its surroundings, spot anomalies and make decisions during inspections without constant operator involvement.
For robotics, this is an important shift. For a long time robots could do a lot, but only if a human had described the scenario in advance almost like a program. The more complex the task, the harder it was to build a convenient interface. The idea behind embodied AI, meaning AI with a physical body and access to the real world, is precisely to close that gap.
Boston Dynamics is one of the few companies that has taken walking robots to commercial scale: Spot is already deployed in the thousands. So integrating a new model is not an academic experiment but an attempt to improve a product already in use on sites.
The main use case is not the household chores seen in videos, but industrial inspection. At factories, energy facilities and other complex sites, Spot is meant to patrol the area and check whether anything dangerous is happening. With Gemini Robotics-ER 1.6, the robot can autonomously look for spilled liquids and foreign debris, read complex sensors, pressure gauges and sight glasses, and call on vision-language models when it needs to understand the situation around it more precisely. In other words, the goal is not to teach a robot to fetch things gracefully, but to reduce risk where the cost of a missed problem can be high.
But the most interesting part is what the developers mean by understanding and reasoning. These words are heard more and more often in robotics, though in practice they mean not philosophy but how closely a machine's behavior approaches human logic. If a person asks a robot to clear cans from a room, they expect not just that the command is carried out, but common sense: pick up the can so as not to spill the remaining liquid, not put a glass of water on the edge of a table, not create a new hazard while removing an old one.
Google DeepMind says it tracks such cases through internal semantic safety scenarios. The goal is for the robot not merely to understand the verb in a command, but to account for the consequences of its action in the physical world.
Still, the limitations of the current approach are quite visible. The current version of the model for Spot relies mainly on vision. For example, one of the new features assesses whether an object was grasped successfully using several cameras. That is useful, but robotics has long had other ways to tell that an object is held securely: force sensors, touch sensors, contact feedback.
The problem is data. The internet has plenty of visual examples of how to pick up a pen or open a door, but almost no large datasets with tactile information. That makes teaching models the physics of contact much harder, for now, than teaching them images and text. To close this gap, Boston Dynamics plans to collect more field data from customers who will use Spot's new inspection features.
There is also a second practical question: trust. Boston Dynamics openly acknowledges that it is rolling out new capabilities through beta programs and only advertises what it is confident in. Commercial inspection does not require absolute perfection from a robot, but there is a usefulness threshold. If a system makes mistakes too often and raises false alarms, operators stop listening to it. The company believes real value begins somewhere above 80 percent, when the robot helps rather than annoys. This matters especially at sites where some critical infrastructure is fitted with sensors, while some potentially dangerous small issues can still only be noticed by eye during a walkaround.
The takeaway is simple: the partnership between Boston Dynamics and Google DeepMind is not about yet another flashy video of a robot dog, but an attempt to turn embodied AI into an applied tool with measurable benefits. If Spot truly learns to reliably notice leaks, read instruments and act more safely in ambiguous environments, the market will get one of the first convincing examples of reasoning AI working not on a screen but on the factory floor. The experience gained can then be carried over to other platforms, including more complex humanoid robots.
- Nov 2, 2026Karpathy builds a YouTube clone with 6454 videos from Hacker News recommendations in two hours
- Nov 2, 2026Karpathy used Claude to build HackerTube from 6,454 videos recommended on Hacker News
- Nov 2, 2026Anthropic needs to grow revenue 32% a year to cover $850 billion in contracts
- Nov 2, 2026Bun creator uses Claude Code to port 750K lines from Zig to Rust in 11 days
Test Frontier LLMs & Autonomous Agents in One Workspace
Run Claude Opus 5.5, GPT-6, Gemini 3.1, and DeepSeek side-by-side in Nomad AI (nomadnet.ai) — unified model routing, deep research, and multimodal workflows under one subscription.
The AI world, distilled — once a week
Seven stories that actually mattered, hand-picked. No noise, no reposts, no press releases.
Done! Check your inbox for a confirmation.