Two-Legged Trouble: Why AI Can Write Code but Trips on a Doorstep
While GPT-5 gears up to conquer the world, top humanoids like Figure or Tesla Optimus still walk as if they had one too many at the bar last night. The problem isn't the "brains" but physics, and Moravec's paradox. What comes naturally to a human, such as keeping balance, demands colossal computation and instant actuator response from a machine. A 20-millisecond signal delay turns a graceful helper into a heap of scrap metal. Until we close the gap between simulation and reality, the machine uprising will look rather clumsy. The real breakthrough will come when neural networks control not just pixels but every micro-movement of the hydraulics in real time.
AI-processed from Habr AI; edited by Hamidun News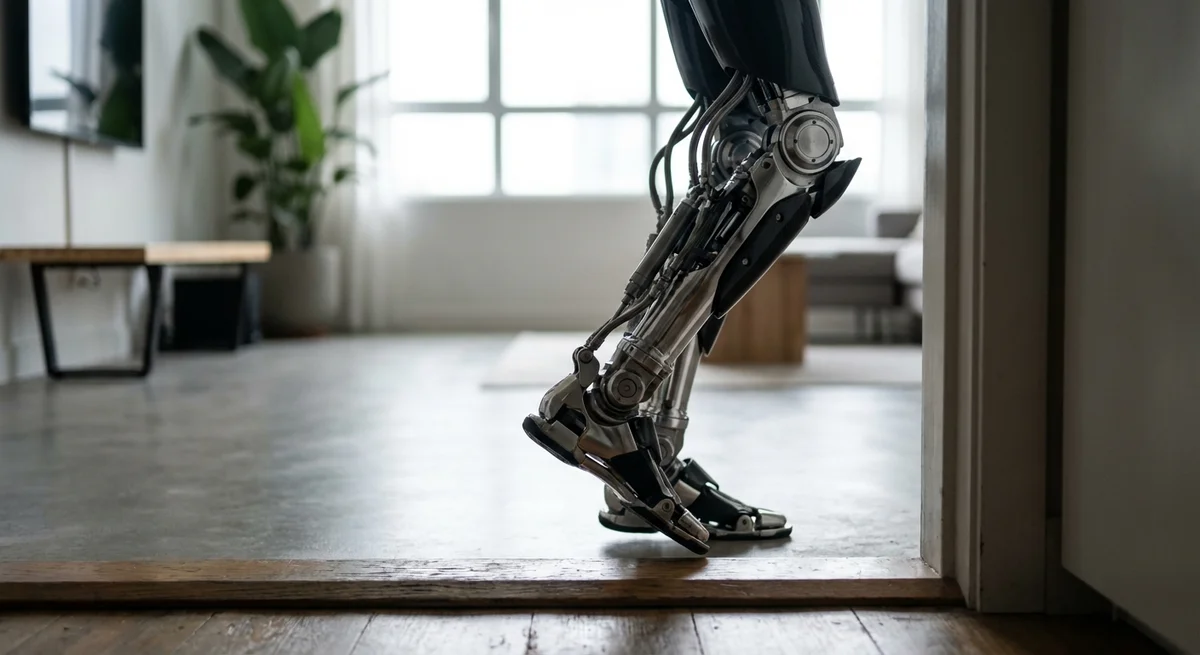
Picture this: an artificial intelligence writes extremely complex Python code in a couple of seconds, composes a symphony in the style of Bach and makes a medical diagnosis more accurately than a panel of doctors. But as soon as that same intelligence is "loaded" into a metal body and tries to simply walk to the kitchen, the trouble begins. It stumbles over a carpet, freezes before a threshold and ends up falling with the grace of a sack of potatoes. It seems absurd in 2026, but the physical world remains the hardest playground for algorithms. We got used to thinking that reasoning is the higher function and walking is something primitive. Reality turned out to be exactly the opposite.
Robotics has long had what is known as Moravec's paradox. Its essence is simple: high-level reasoning requires very little computing power, while low-level sensorimotor skills require enormous resources. It is easy to teach a computer to play chess at grandmaster level, because chess is a logical structure with clear rules. But teaching a robot to feel the surface of a table or balance on one leg is a real nightmare for engineers. Evolution spent millions of years refining our vestibular system and muscle response, and we are trying to reproduce it with servo drives and lithium batteries in a couple of decades.
The core problem lies in latency and feedback. When you walk on uneven ground, your brain receives thousands of signals from muscles and joints in real time, correcting your body position before you even realize you stepped on a stone. In a modern robot, this loop looks different. Cameras see the obstacle, the processor handles the image, the algorithm makes a decision, and only then does the signal go to the motors. If this chain takes even 50 milliseconds longer than it should, gravity takes its toll. In games we call this "ping", but for a robot weighing 80 kilograms, high ping means expensive repairs.
There is also a huge gulf between simulation and reality, which specialists call the sim-to-real gap. In the virtual environment where neural networks learn to control a body, physics is perfect. There is no dust in the bearings, no voltage sag in the battery and no microscopic bumps in the floor.
When a model trained in the "digital" world is moved to real hardware, it runs into the chaos of the physical world. Every actuator has its own backlash, every sensor is noisy, and the system starts to "lag". Companies such as Figure and Boston Dynamics are now trying to solve this with end-to-end learning, where a neural network links the visual stream directly to motor voltage, bypassing the intermediate layers of classical programming.
Nor should we forget purely mechanical limits. The human foot is an engineering masterpiece of 26 bones and many ligaments that works as a perfect shock absorber. Most modern robots have a rigid, "hoof-like" plate instead of a foot, or at best a joint with limited degrees of freedom. We are trying to make a piece of metal imitate biological tissue, which is naturally elastic and able to store energy. Until we build new types of actuators that work like artificial muscles, robots' gait will stay "wooden" and unsteady.
The future, of course, belongs to neuromorphic chips and new materials, but for now we should temper our expectations of home robot helpers. Most likely, the first machines to enter our homes will not be two-legged athletes but wheeled platforms with manipulators, simply because they are cheaper and more reliable. Gravity is a harsh mistress, and it does not forgive code errors when they involve moving an iron body through space. We are at the point where intelligence is ready to hold philosophical conversations, yet still fears an ordinary bathroom threshold.
Key takeaway: Walking is not a problem of "intelligence" but of reaction speed and imperfect mechanics. Until hardware catches up with software in flexibility and responsiveness, humanoids will remain expensive toys for laboratories.
- Oct 28, 2026Anthropic reveals how it builds Claude with Claude: the brain separate from the hands
- Oct 28, 2026Bayer Launches Multi-Agent Engine on AgentCore: 80% of Questions Handled Without Engineers
- Oct 28, 2026Liquid AI releases LFM2.5-24B-A2B: an agent model with 2B active parameters
- Oct 28, 2026AgentOrch: Pre-Planned AI Agents Now Trail Step-by-Step Execution by Just 8.5 Points
Test Frontier LLMs & Autonomous Agents in One Workspace
Run Claude Opus 5.5, GPT-6, Gemini 3.1, and DeepSeek side-by-side in Nomad AI (nomadnet.ai) — unified model routing, deep research, and multimodal workflows under one subscription.
The AI world, distilled — once a week
Seven stories that actually mattered, hand-picked. No noise, no reposts, no press releases.
Done! Check your inbox for a confirmation.